Research
AI that perceives, reasons about and acts in physical space
RESEARCH DIRECTION
Structured Spatial World Models
Our world models are structured. They represent the world as 3D geometry, objects, relations and physics, not just pixels, so that robots, drones and satellites can reason about the world and act in it. What they learn from acting flows back to update the model.
Research Areas
All 5 research areas →-
 01
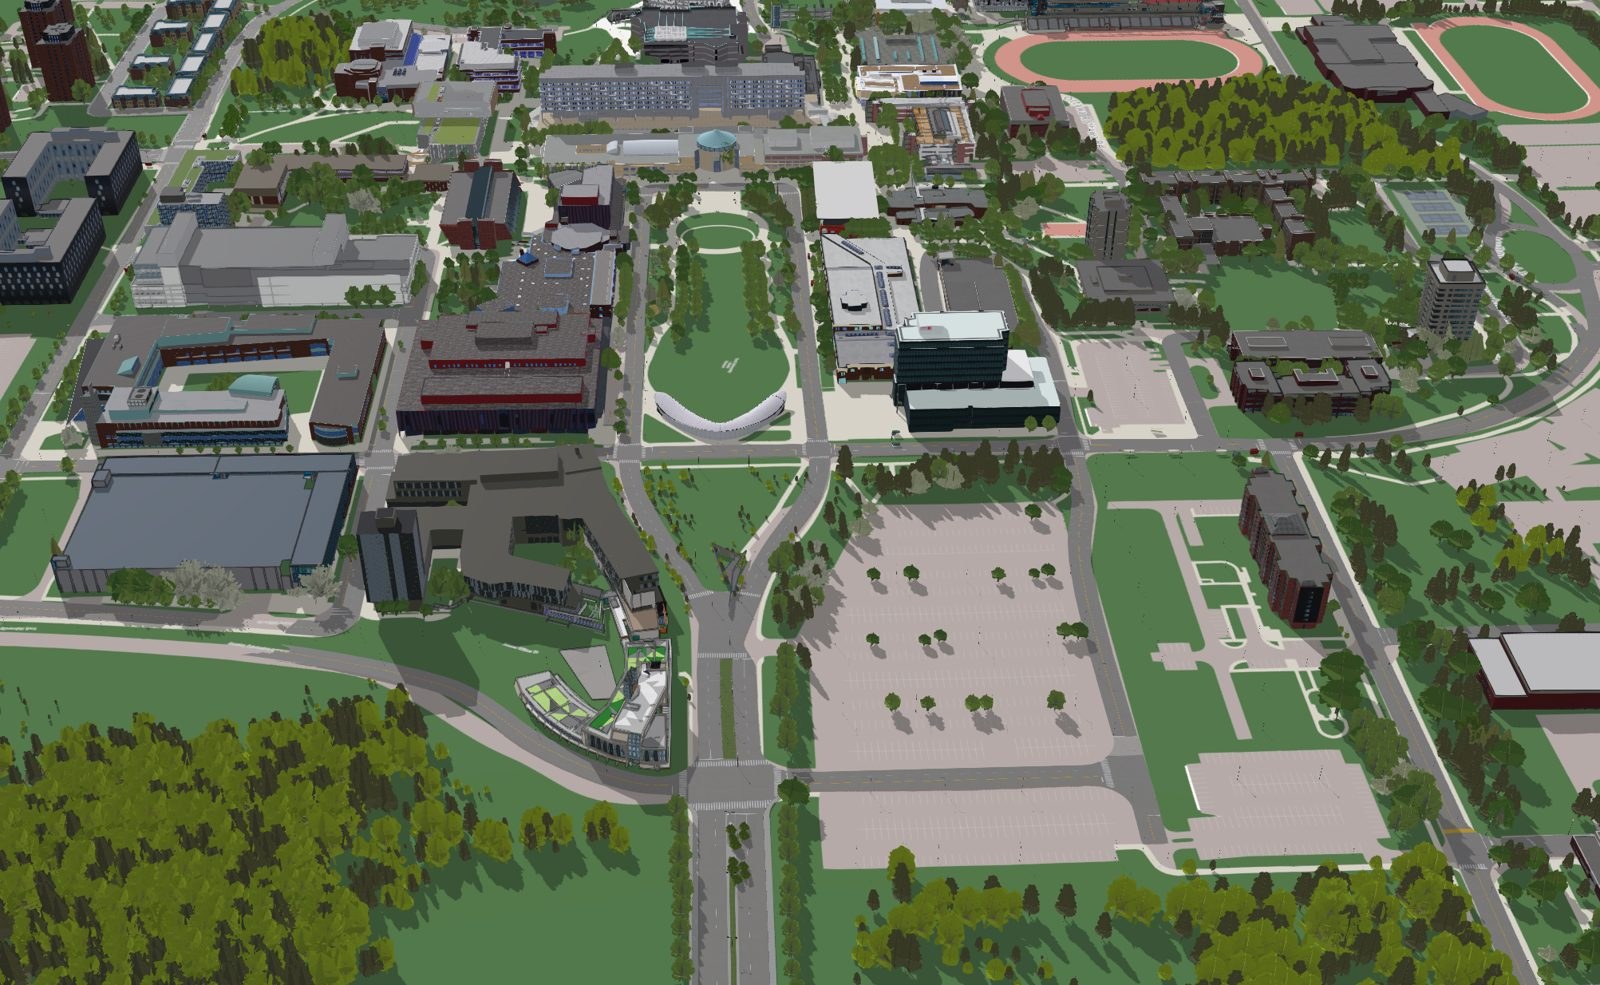
Urban World Models
Graph models that understand and predict robots and mobility in cities
Explore →
-
 02
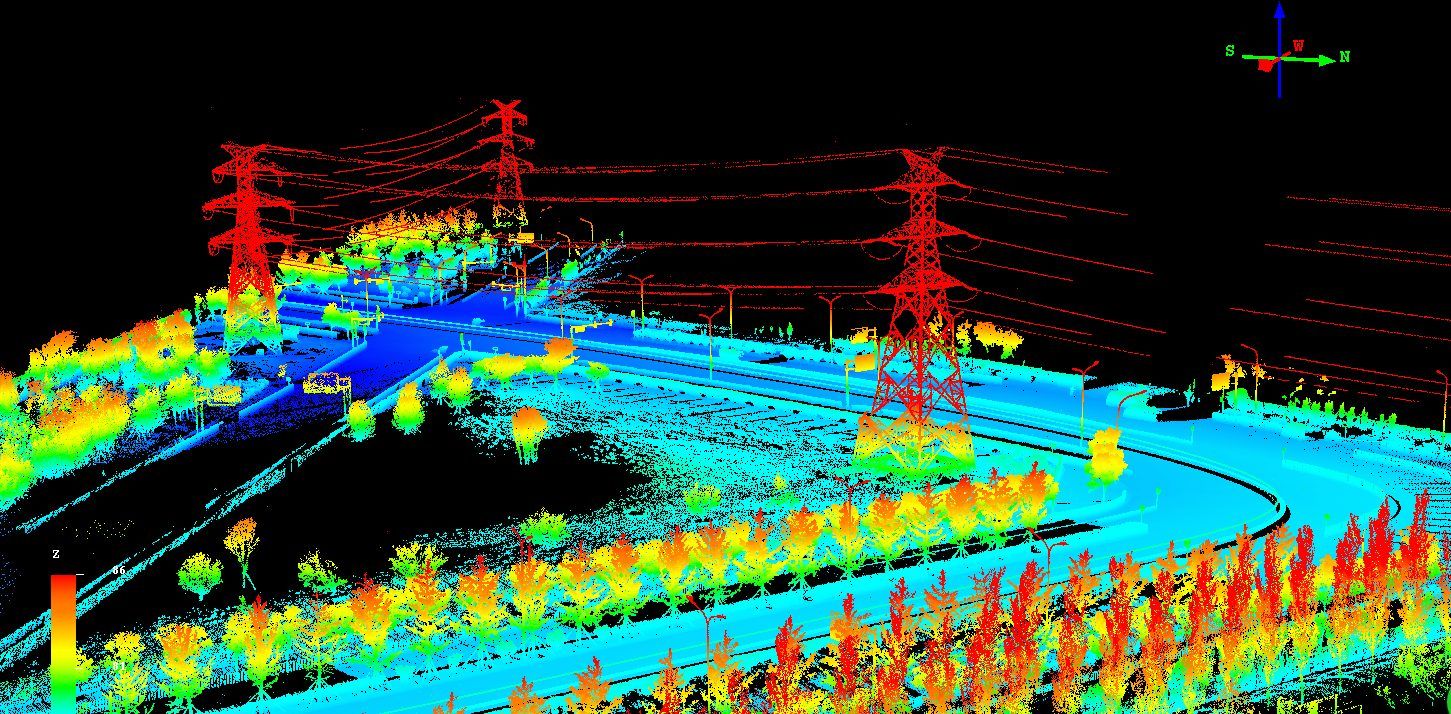
Scan-to-Model
Infrastructure models with engineering knowledge, built from scans
Explore →
-
 03
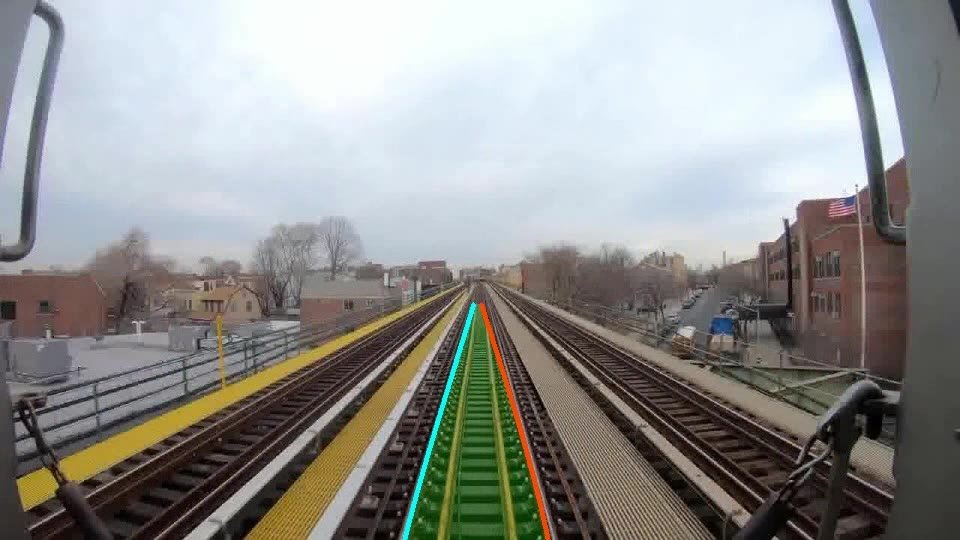
Embodied Autonomy
Robots, drones and cars that sense, map and act in real time
Explore →
-
 04
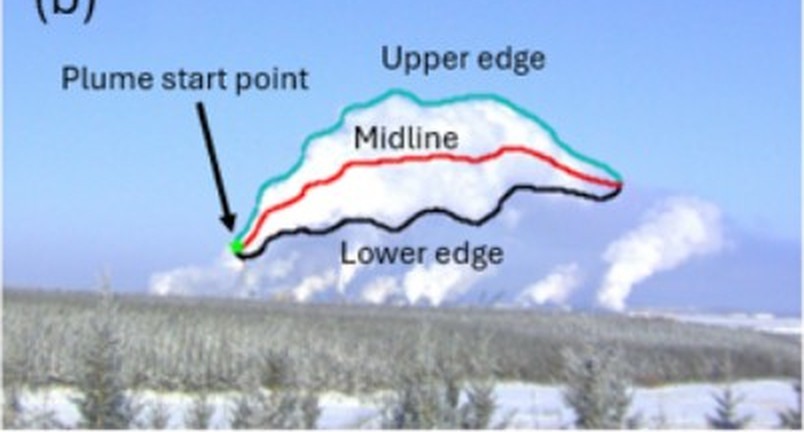
Physics-Informed Earth AI
AI guided by physics that emulates Earth systems
Explore →
-
 05
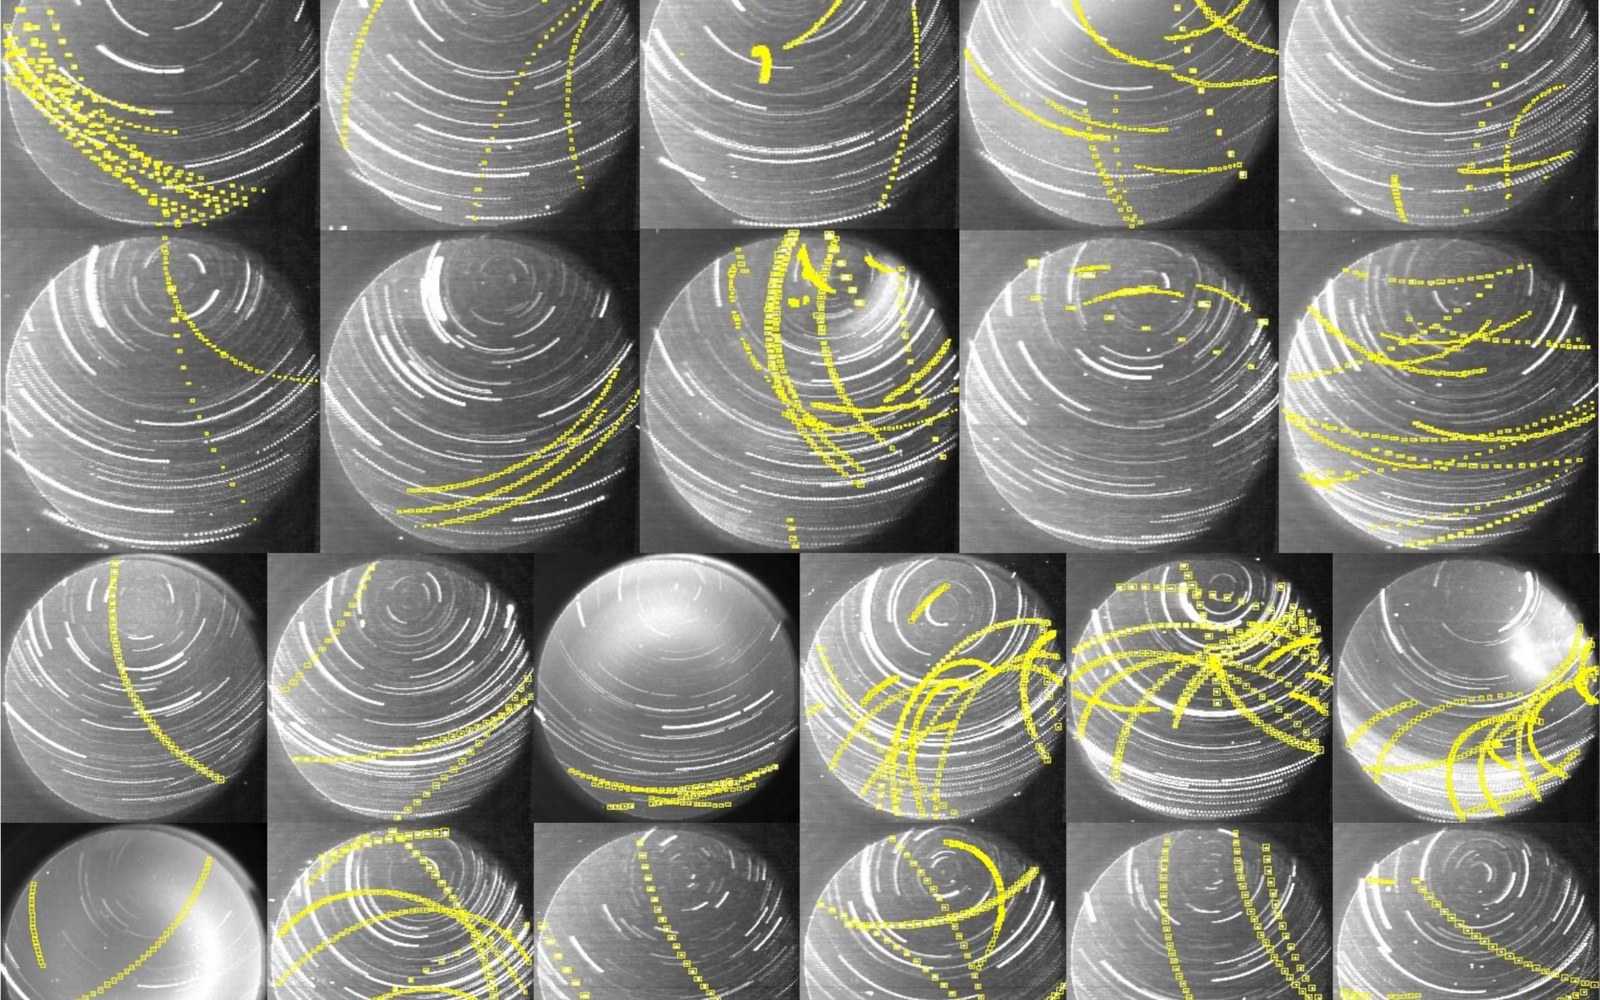
Space Situational Awareness
Space in the loop: detecting and tracking objects in orbit
Explore →
Projects
All 5 projects → 3DMMAI
3D Mobile Mapping Artificial Intelligence (3DMMAI), is supported by the NSERC (Natural Sciences and Engineering Research Council of Canada) Collaborative Research Development (CRD) program and Teledyne Optech in…
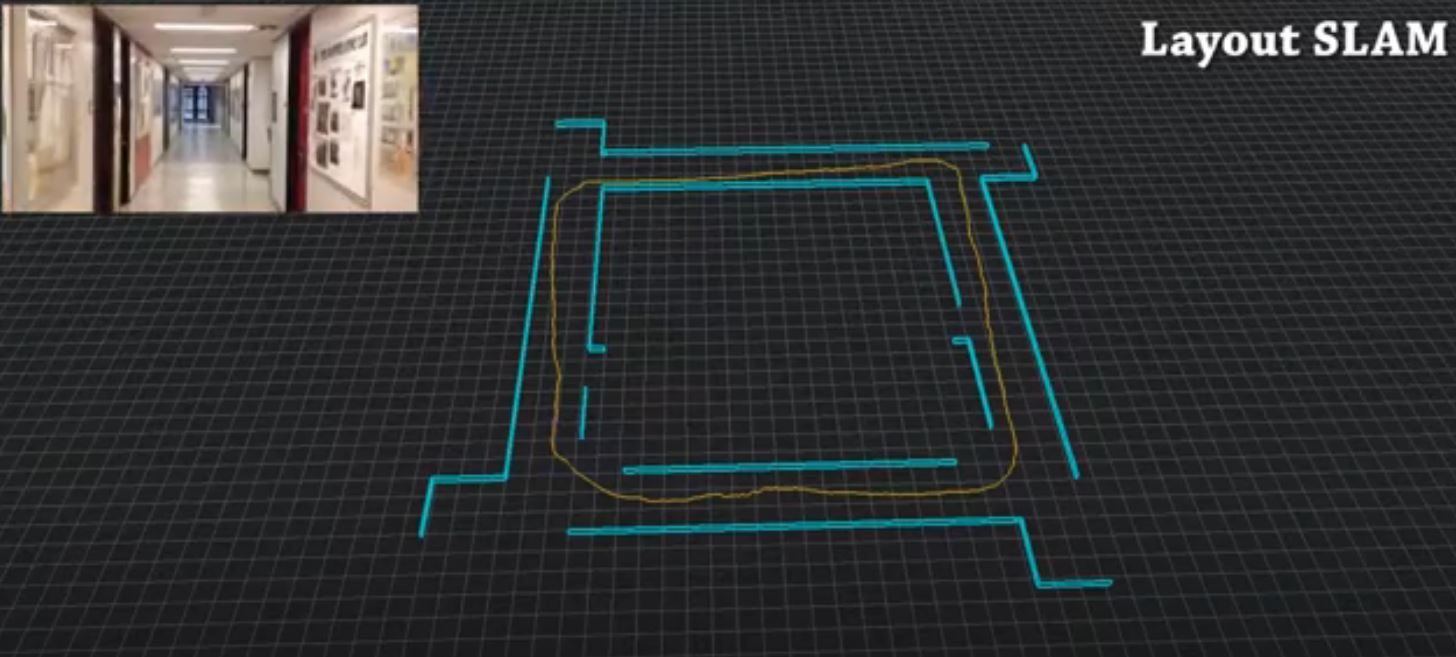 Layout SLAM
In this project, we study the role of high-level geometric topological cues such as 3D primitive representation of indoor corridors to improve the performance of simultaneous localization and modelling (SLAM) using a…
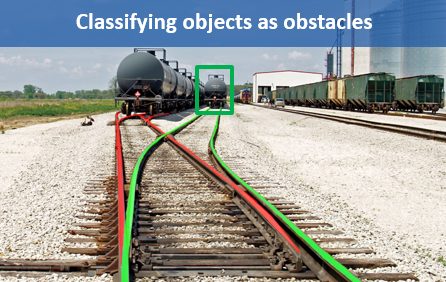 OnTRAC
Ontario Train Autonomy Collaboration (OnTRAC) Project (April 2019 – March 2021) is to develop and demonstrate a prototype system of a high-performance Obstacle Detection, Classification and Tracking (ODCT) solution to…
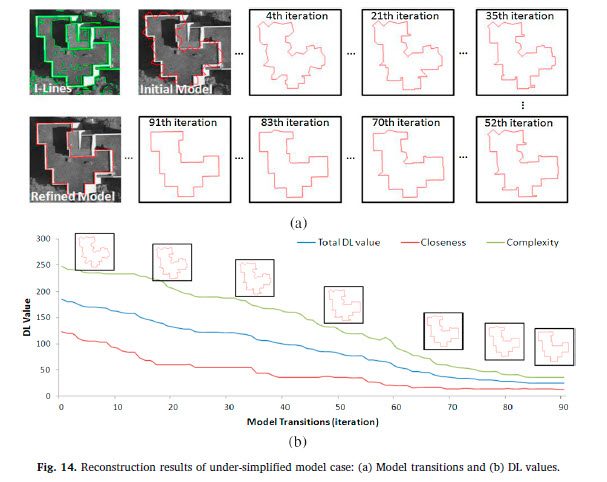 Progressive 3D City Modelling
Dr. Jaewoo Jung published his research work on 3D building modeling methods in the ISPRS Journal ( doi.org/10.1016/j.isprsjprs.2019.01.003) . This journal suggests an innovative method for automatically updating an…
 Q-Drone
 is a research-oriented unmanned aerial vehicle (UAV), which provides objective path planning to meet the requirements of critical infrastructure mapping such as the complete and homogeneous quality of…
Videos
All 19 videos →Research Collaborators
All 47 collaborators →