Research / Research areas
Research Areas
Our five research areas, with every topic and who works on it.
01 · UNDERSTAND AND PREDICT CITIES
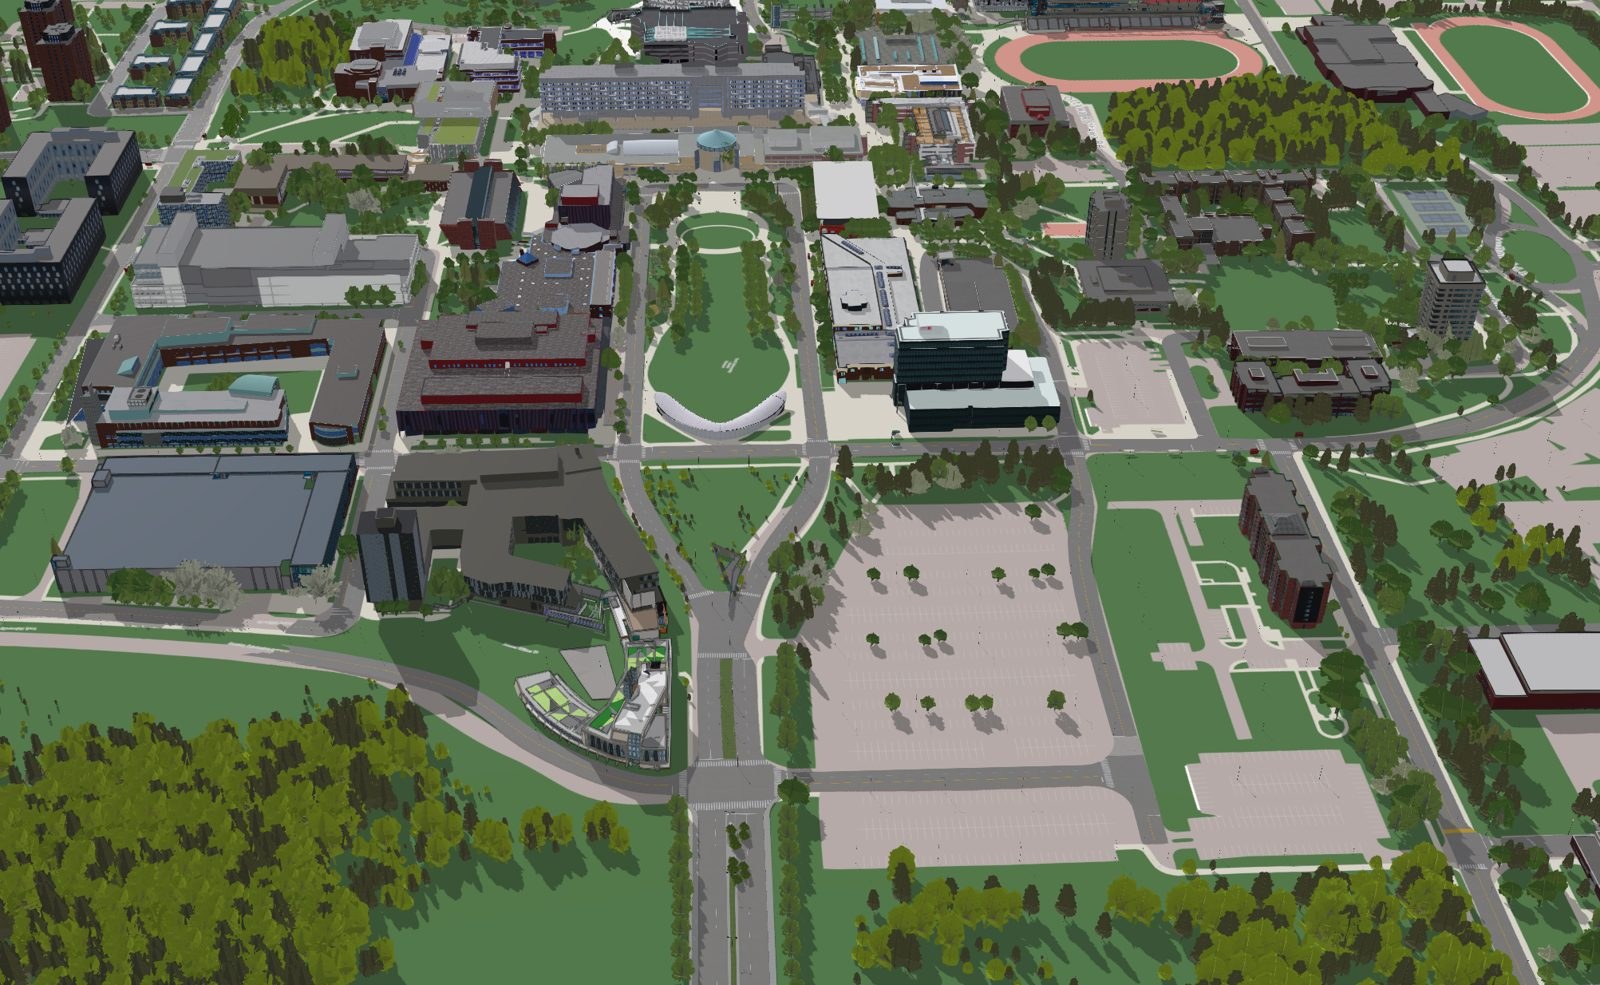
We build graph models of cities that link streets, buildings, people, robots and vehicles. They let us predict how people and machines move and test changes before they are made.
- Spatial knowledge graph + LLM agentsMd. Ehsan Shahmi Chowdhury
- Pedestrian trajectories in Toronto and SeoulMohammadjavad Ghorbanalivakili
- Robots and people sharing city spaceLooking for students
Explore Urban World Models →
02 · FROM SCANS TO ENGINEERING MODELS
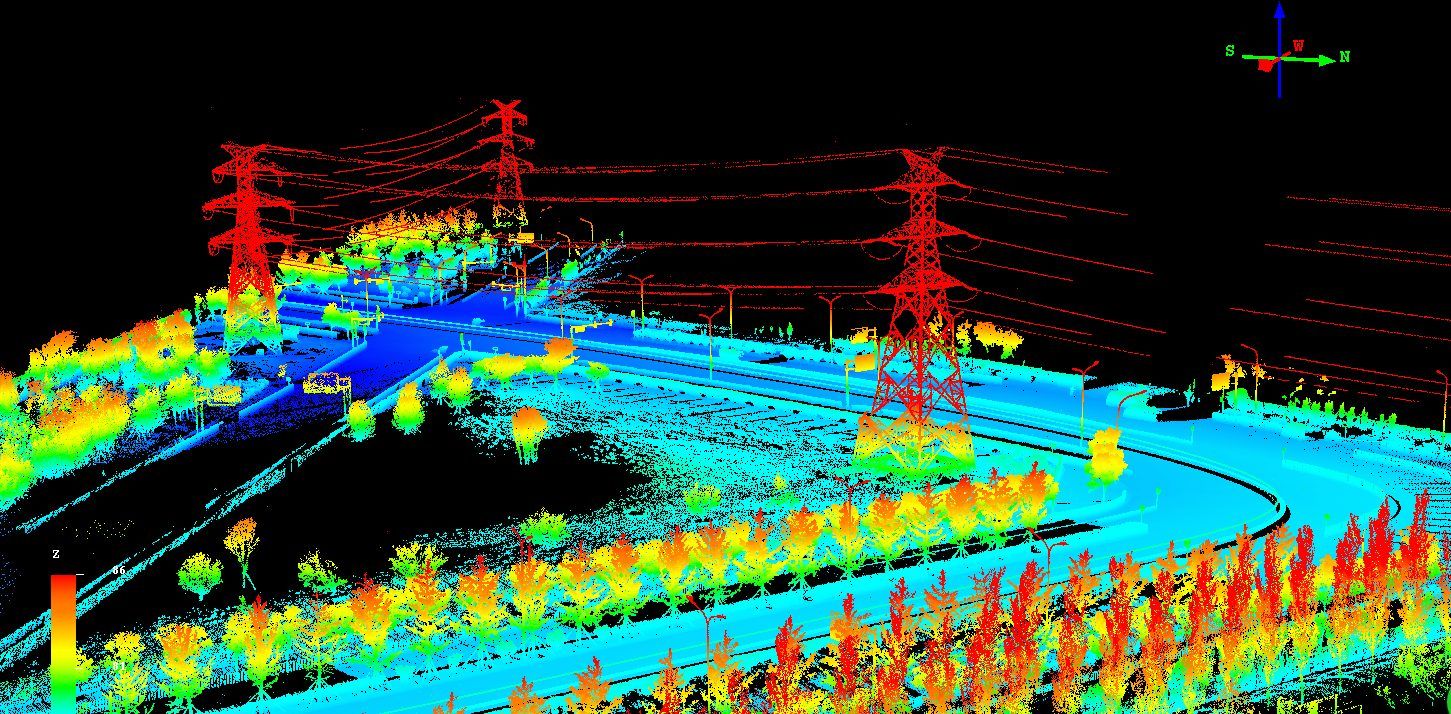
We turn LiDAR and images into clean 3D models of buildings and infrastructure that carry engineering knowledge, from LoD1 to LoD3 and BIM.
- LoD1 to LoD2 building reconstructionMohammad Moein Sheikholeslami
- Semantic BIM/IFC digital twinsMd. Ehsan Shahmi Chowdhury
- Single-view 3D reconstruction with diffusion priorsYoussef Korny
- Point cloud upsampling and image–LiDAR fusionSunghwan (Jacob) Yoo, Youssef Korny
- Gaussian splatting for 3D city modelsLooking for students
Explore Scan-to-Model →
03 · SENSE, MAP AND ACT IN REAL TIME
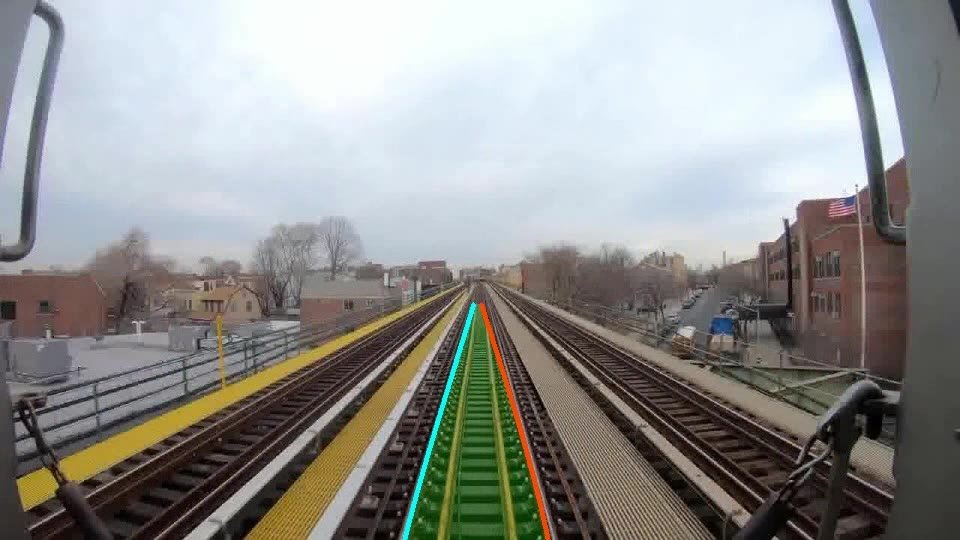
Robots, drones, trains and cars need to see, map and decide in real time. We build the perception and mapping that lets them act safely on their own.
- Vision-language models for autonomous trainsMohammadjavad Ghorbanalivakili, Ashley Varghese
- Autonomous mapping agents for dronesLooking for students
- 3D-grounded vision-language-action modelsLooking for students
Explore Embodied Autonomy →
04 · AI THAT RESPECTS PHYSICS
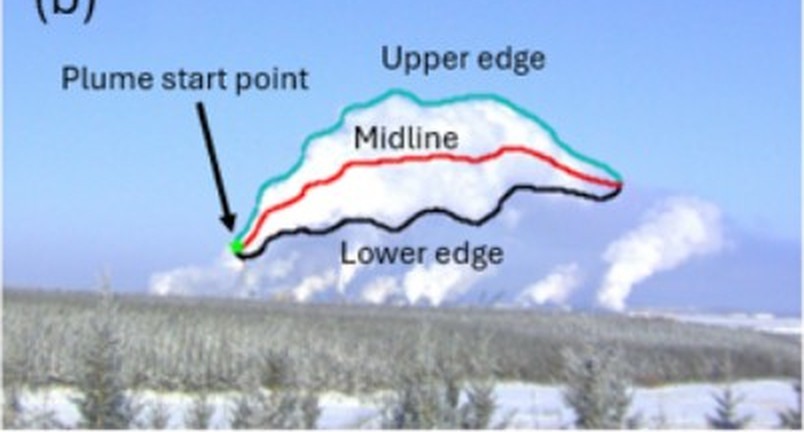
We combine deep learning with physical models to emulate Earth systems, from smokestack plumes and air quality to airflow around people in cities.
- Plume rise from images for air-quality modelsLooking for students
- CFD-calibrated pedestrian simulationMohammadjavad Ghorbanalivakili
Explore Physics-Informed Earth AI →
05 · SPACE IN THE LOOP
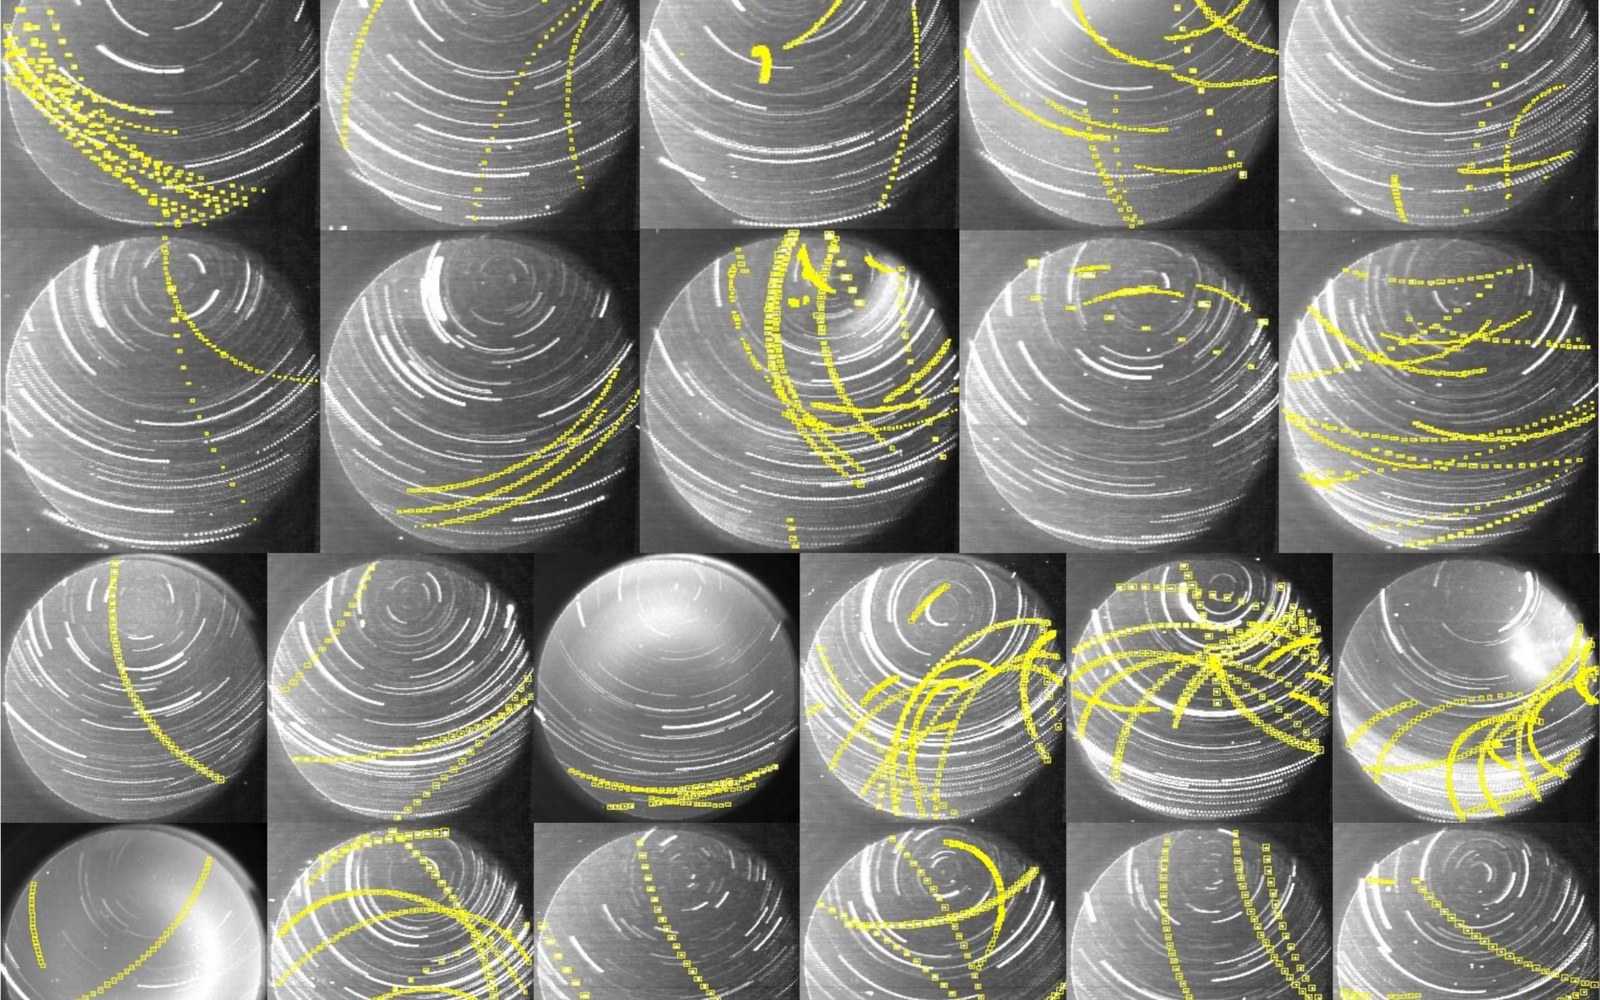
We detect and track objects in orbit from space-based images and predict where they will go next.
- Tiny resident space object (RSO) detectionYoussef Beshir
- Diffusion models for RSO imageryMerna Tamer Youssef
- Orbit determination and propagationLooking for students
Explore Space Situational Awareness →
← Research