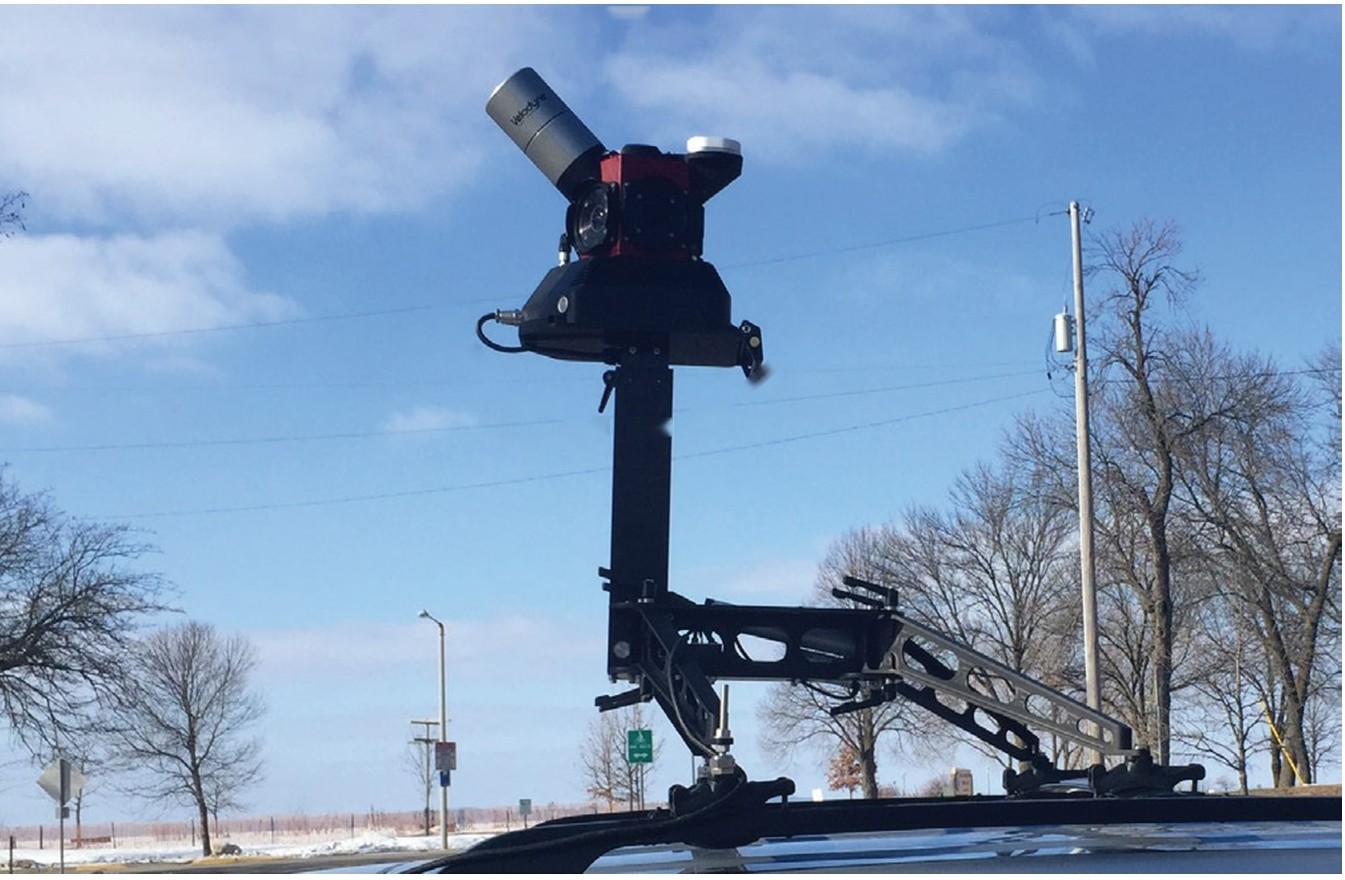
YUTO MMS
A comprehensive SLAM benchmark for urban mobile mapping with tilted LiDAR and panoramic camera integration; four sequences totalling 20.1 km.
IJRR, 2025
Open datasets, benchmarks and code from the lab
GitHubHugging FaceDeep Learning Reading ClubYouTube
Our lab is committed to open science. We publicly release the datasets, benchmarks, and code developed through our research. Most resources are hosted on our GitHub organization and Hugging Face organization.
A comprehensive SLAM benchmark for urban mobile mapping with tilted LiDAR and panoramic camera integration; four sequences totalling 20.1 km.
IJRR, 2025
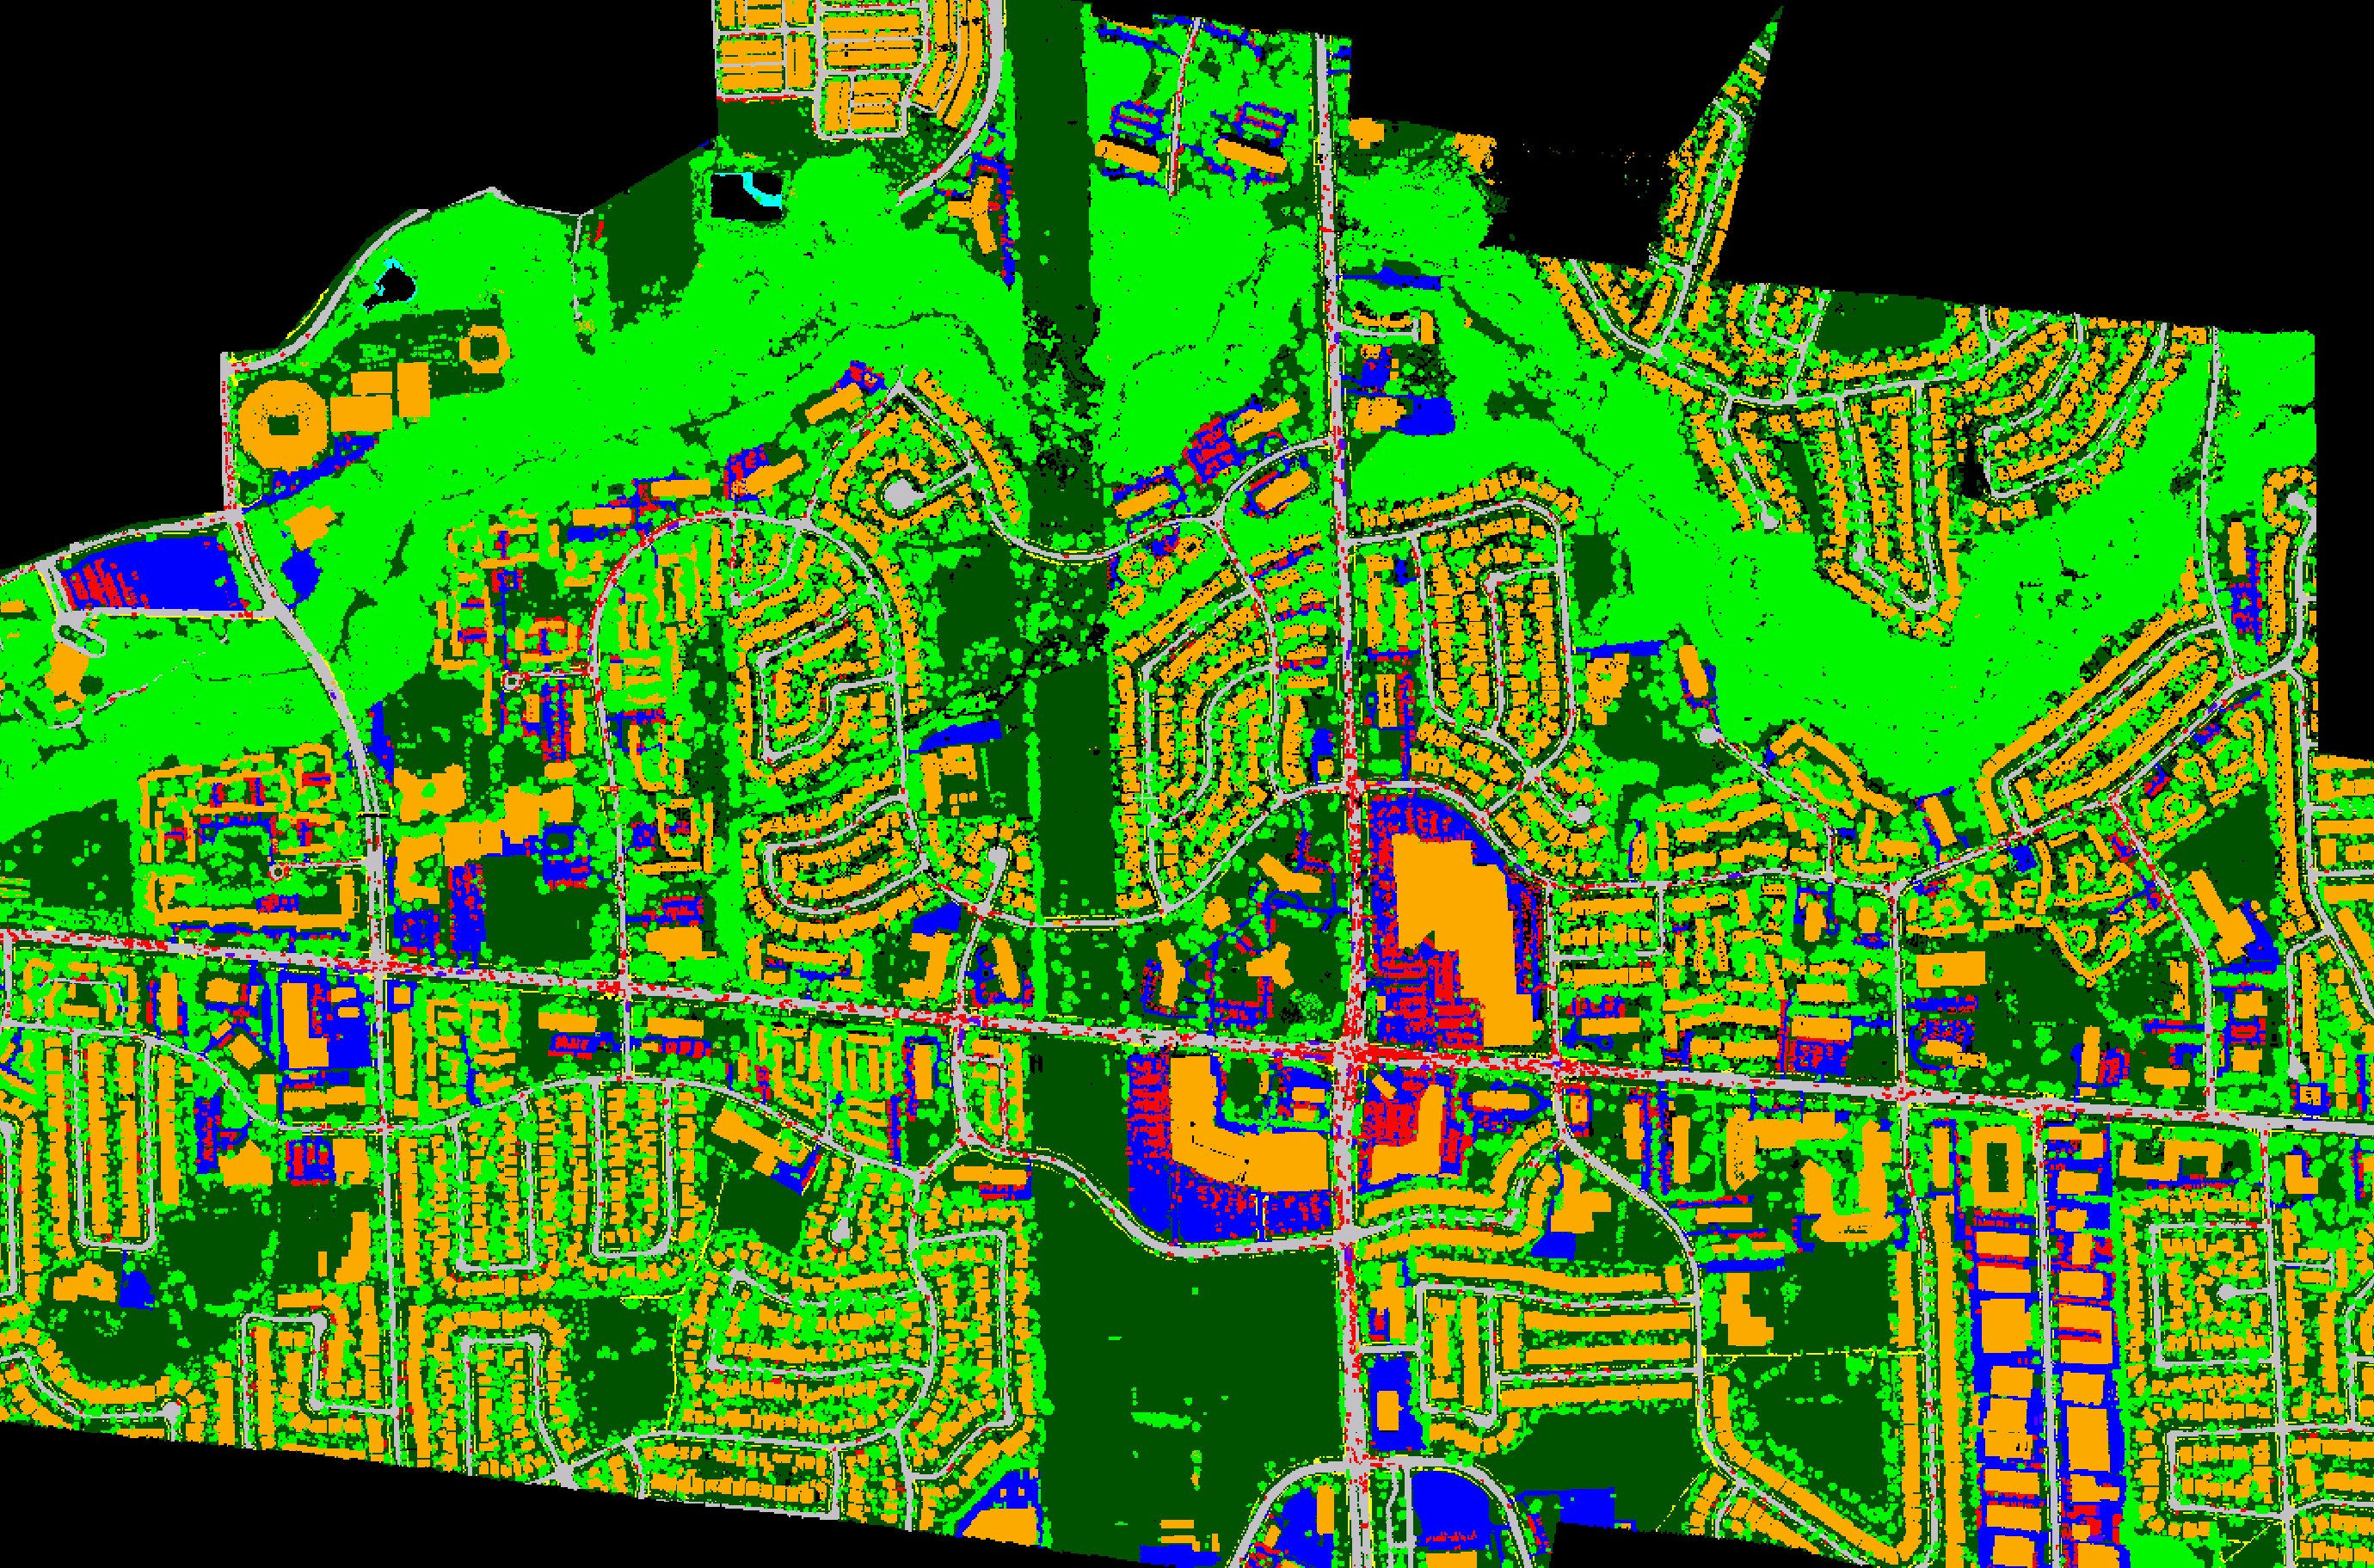
A large-scale aerial LiDAR dataset for 3D semantic segmentation: ~738 million points covering 9.46 km² of the York University campus, annotated with nine semantic classes.
ISPRS Archives, 2023
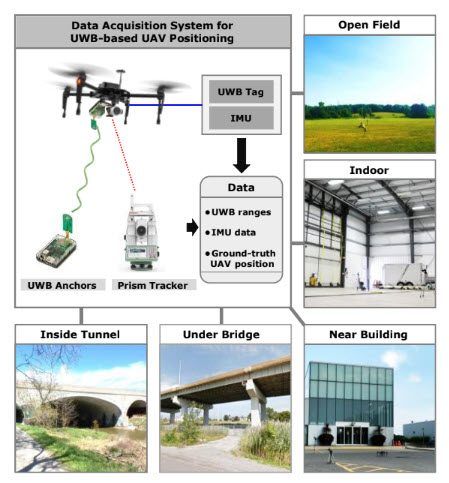
Benchmark dataset of ultra-wideband radio based UAV positioning.
IEEE ITSC, 2020
An on-orbit star-tracker benchmark for resident space object (RSO) detection and attitude estimation: 1,378 calibrated near-infrared images from the CASSIOPE Fast Auroral Imager with 4,237 verified RSO annotations. Led by Vithurshan Suthakar (Prof. Regina Lee's lab) with the AUSM Lab.
Zenodo, 2026
Multi-year indoor positioning dataset from four York University buildings (2021 and 2022): Wi-Fi signal strength, inertial and magnetometer data from Android phones, with HoloLens 2 augmented-reality ground truth. By Afnan Ahmad.
ISPRS IJGI (submitted), 2026
Available on request
A large-scale airborne LiDAR dataset for single tree detection with 5,000 annotated trees.
ICPR Workshops, 2022
Available on request
Image dataset for industrial plume rise measurement.
Federated Research Data Repository, 2026
Available on request
UAV imagery ready for 3D reconstruction.
Data in Brief, 2019
Available on request