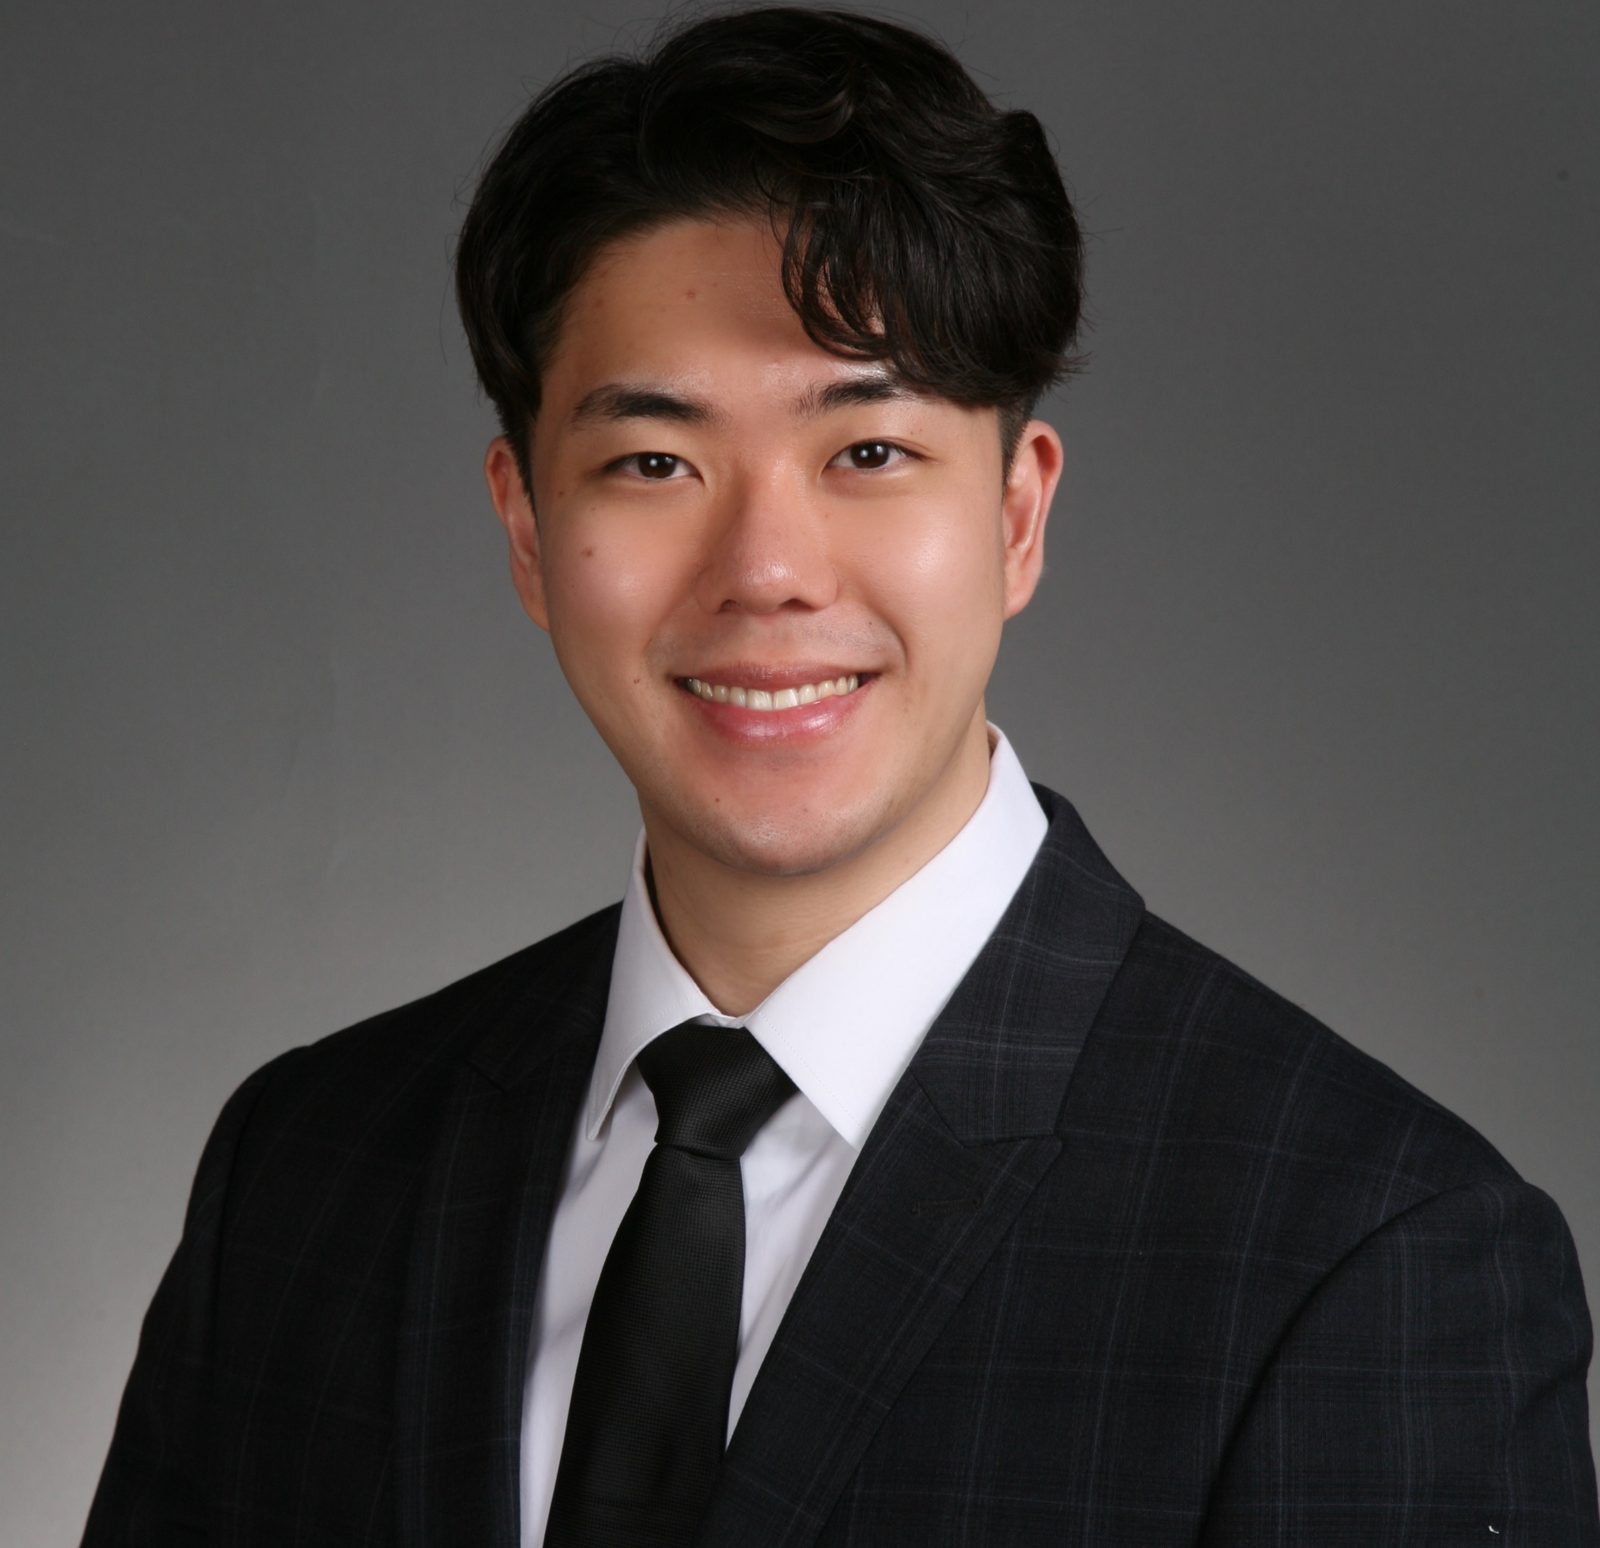
Hyungju Lee has started to work as a research assistant in the fall, 2019. His research focuses on deep learning, computer vision, point cloud, benchmarking, and object detection.
Hyungju is part of OnTRAC: Safe and Robust Obstacle Detection for Autonomous Rail funded by the OCE, Autonomous Vehicle Innovation Network – AV R&D Partnership Fund and collaborate with Neptec (Lead), Thales Transportation, York University and TrackGen.
Experience
- Sep, 2019–Present: Research Assistant, GeoICT/ AUSMLab, York University Canada
- April, 2017–Dec, 2017: Financial Analyst/Auditor, Government of Ontario, Ministry of Natural Resources and Forestry, Land and Resources Cluster, Canada
- April, 2015–Oct, 2015: Summer Workshop Assistant, University of Toronto Scarborough, MSLC (Math & Science Learning Centre), Canada
- Jun, 2013–April, 2014: Auditing Guard, NICE CMS (National Information & Credit Evaluation Cash Management Service)
- Sep, 2011–Jun, 2013: Military Police Officer, Republic of Korea Marine Corps, 2nd Division, MP dept. South Korea
Publications (2)
2023
- Yoo, S., Ko, C., Sohn, G., and Lee, H. (2023). YUTO Semantic: A Large Scale Aerial LiDAR Dataset for Semantic Segmentation. Int. Arch. Photogramm. Remote Sens. Spatial Inf. Sci.
- Ko, C., Jeong, Y., Lee, H., and Sohn, G. (2023). YUTO Tree5000: A Large-Scale Airborne LiDAR Dataset for Single Tree Detection. Pattern Recognition, Computer Vision, and Image Processing (ICPR 2022 Workshops), 371-385.